
Robotics: Science and Systems (RSS) 2026
NeuralActuator: Neural Actuation Modeling for Robot Dynamics and External Force Perception
Learned actuator dynamics for robot simulation and sensorless force perception.
PhysAI Lab
We study robot manipulation and physical world modeling through simulation and machine learning.
01 / Research direction
We connect robot interaction, actuation modeling, and physical world construction to simulation and robot learning.
Robotics: Science and Systems (RSS) 2026
Learned actuator dynamics for robot simulation and sensorless force perception.

arXiv preprint · 2026
Recovering physics-based worlds from real interaction using vision-language agents.

Preprint, arXiv:2609.19600 · 2026
Contact-centric deformable world modeling for robot learning.


Preprint, arXiv:2609.33208 · 2026
A verification-guided agent that constructs and checks physically simulatable worlds.
02 / Research direction
We combine numerical methods and neural representations to simulate physical dynamics efficiently, across materials, geometries, and discretizations.

SIGGRAPH Asia 2026 · Conference Track
One Transformer architecture spanning fluids, cloth, solids, granular materials, and molecular dynamics.

ACM SIGGRAPH/Eurographics Symposium on Computer Animation (SCA), Computer Graphics Forum · 2026
Equation-free cyclic animation through learned Koopman surrogates.

ACM Transactions on Graphics (Proceedings of SIGGRAPH) · 2025
A temporally-aware reduced basis for fast fluid simulation.

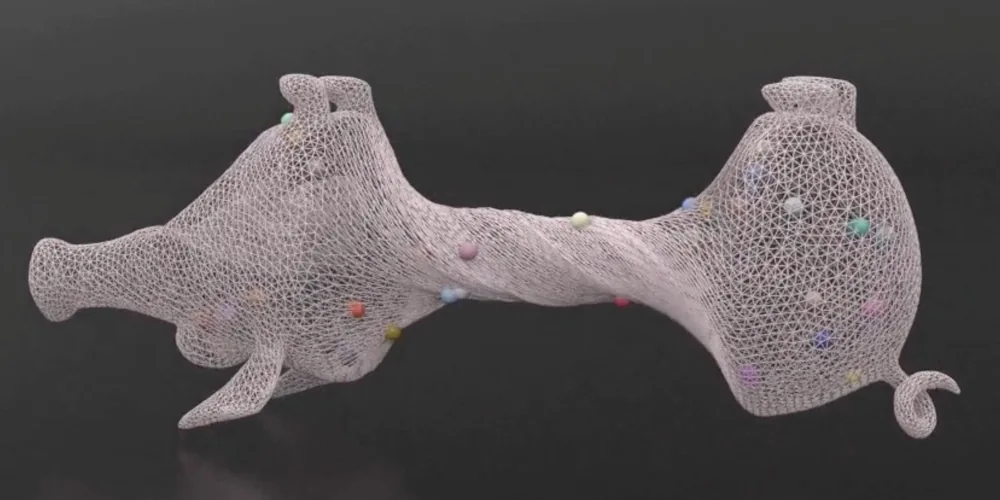
International Conference on Learning Representations (ICLR) 2023 notable-top-25%
03 / Research direction
We develop geometric representations and optimization tools for physical constraints, computational design, and scientific computing.
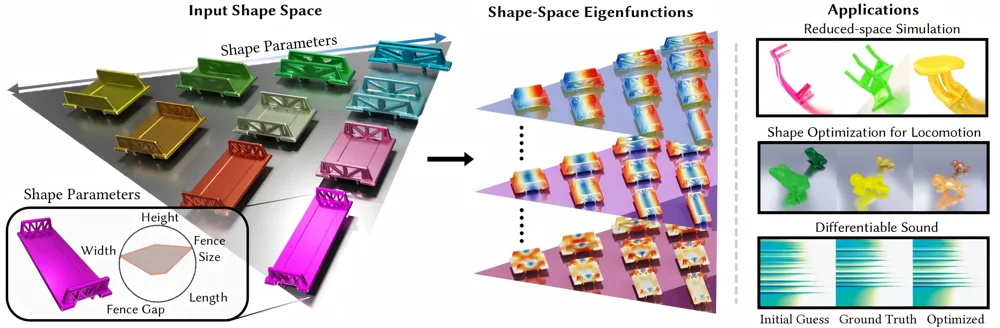
SIGGRAPH 2025
Eigenanalysis across continuously parameterized shape families for simulation and design.
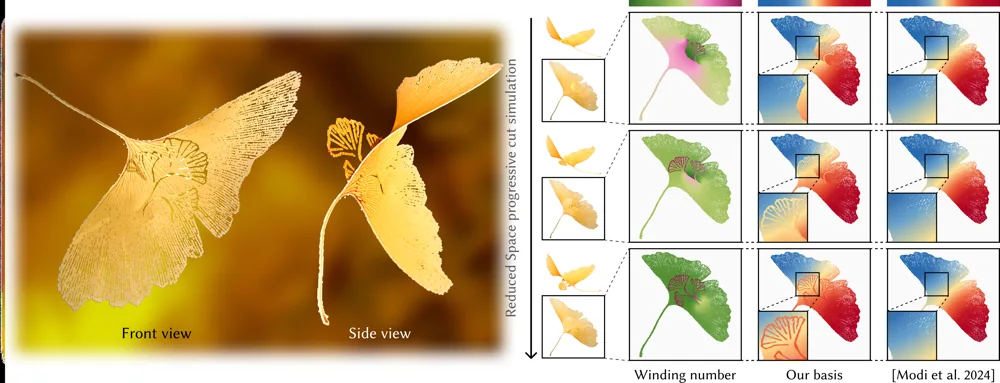
SIGGRAPH 2025
Neural fields that represent precise cuts and discontinuities for physics simulation.
International Conference on Learning Representations (ICLR) · 2026
Differentiable Gauss–Seidel projection for physically valid biomolecular structures.

Preprint, arXiv:2609.36277 · 2026
Registered volumetric geometry for protein representation learning.
A connected research community
Our work connects visual computing, mechanics, scientific machine learning, and robotics. Peter is affiliated with UBC’s AI4Science community and Institute of Applied Mathematics.
Peter and his collaborators also work with industry on simulation challenges. Learn more about these collaborations on Peter’s research profile ↗.